Robotics · 2025
Timed-Vibration Quadruped Locomotion
A quadruped, loose terrain, and timed vibration.
The project
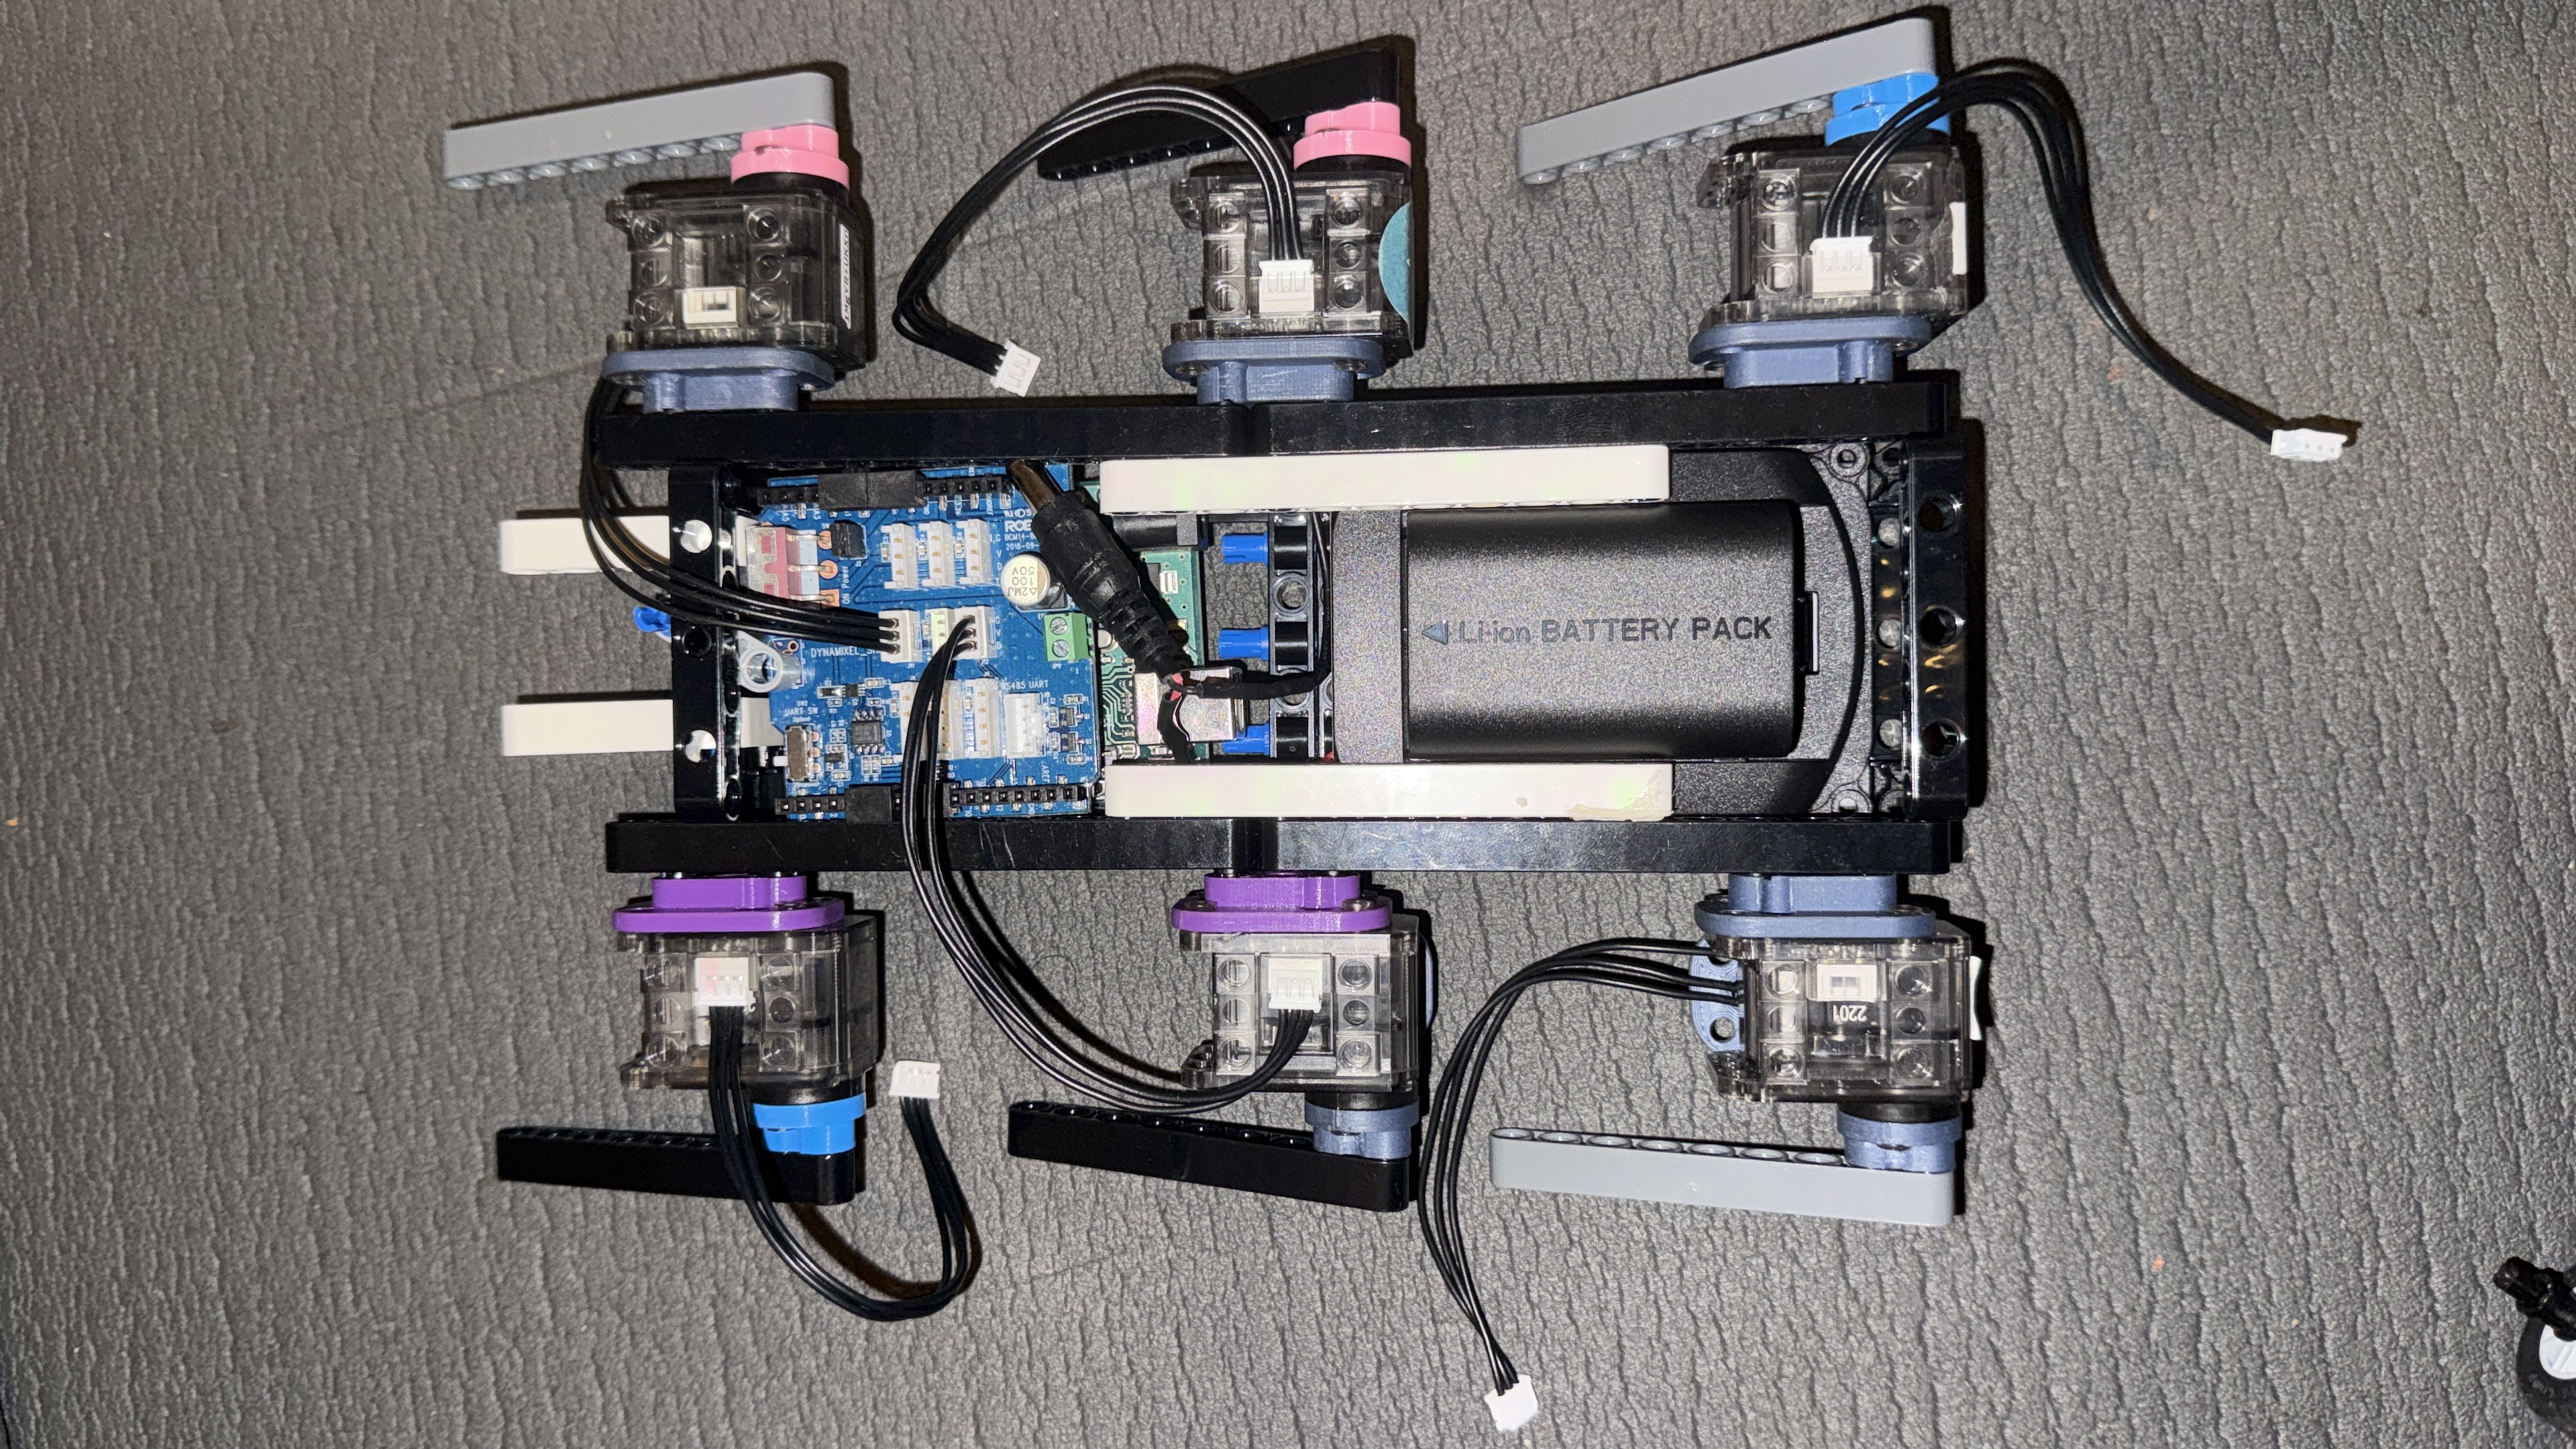
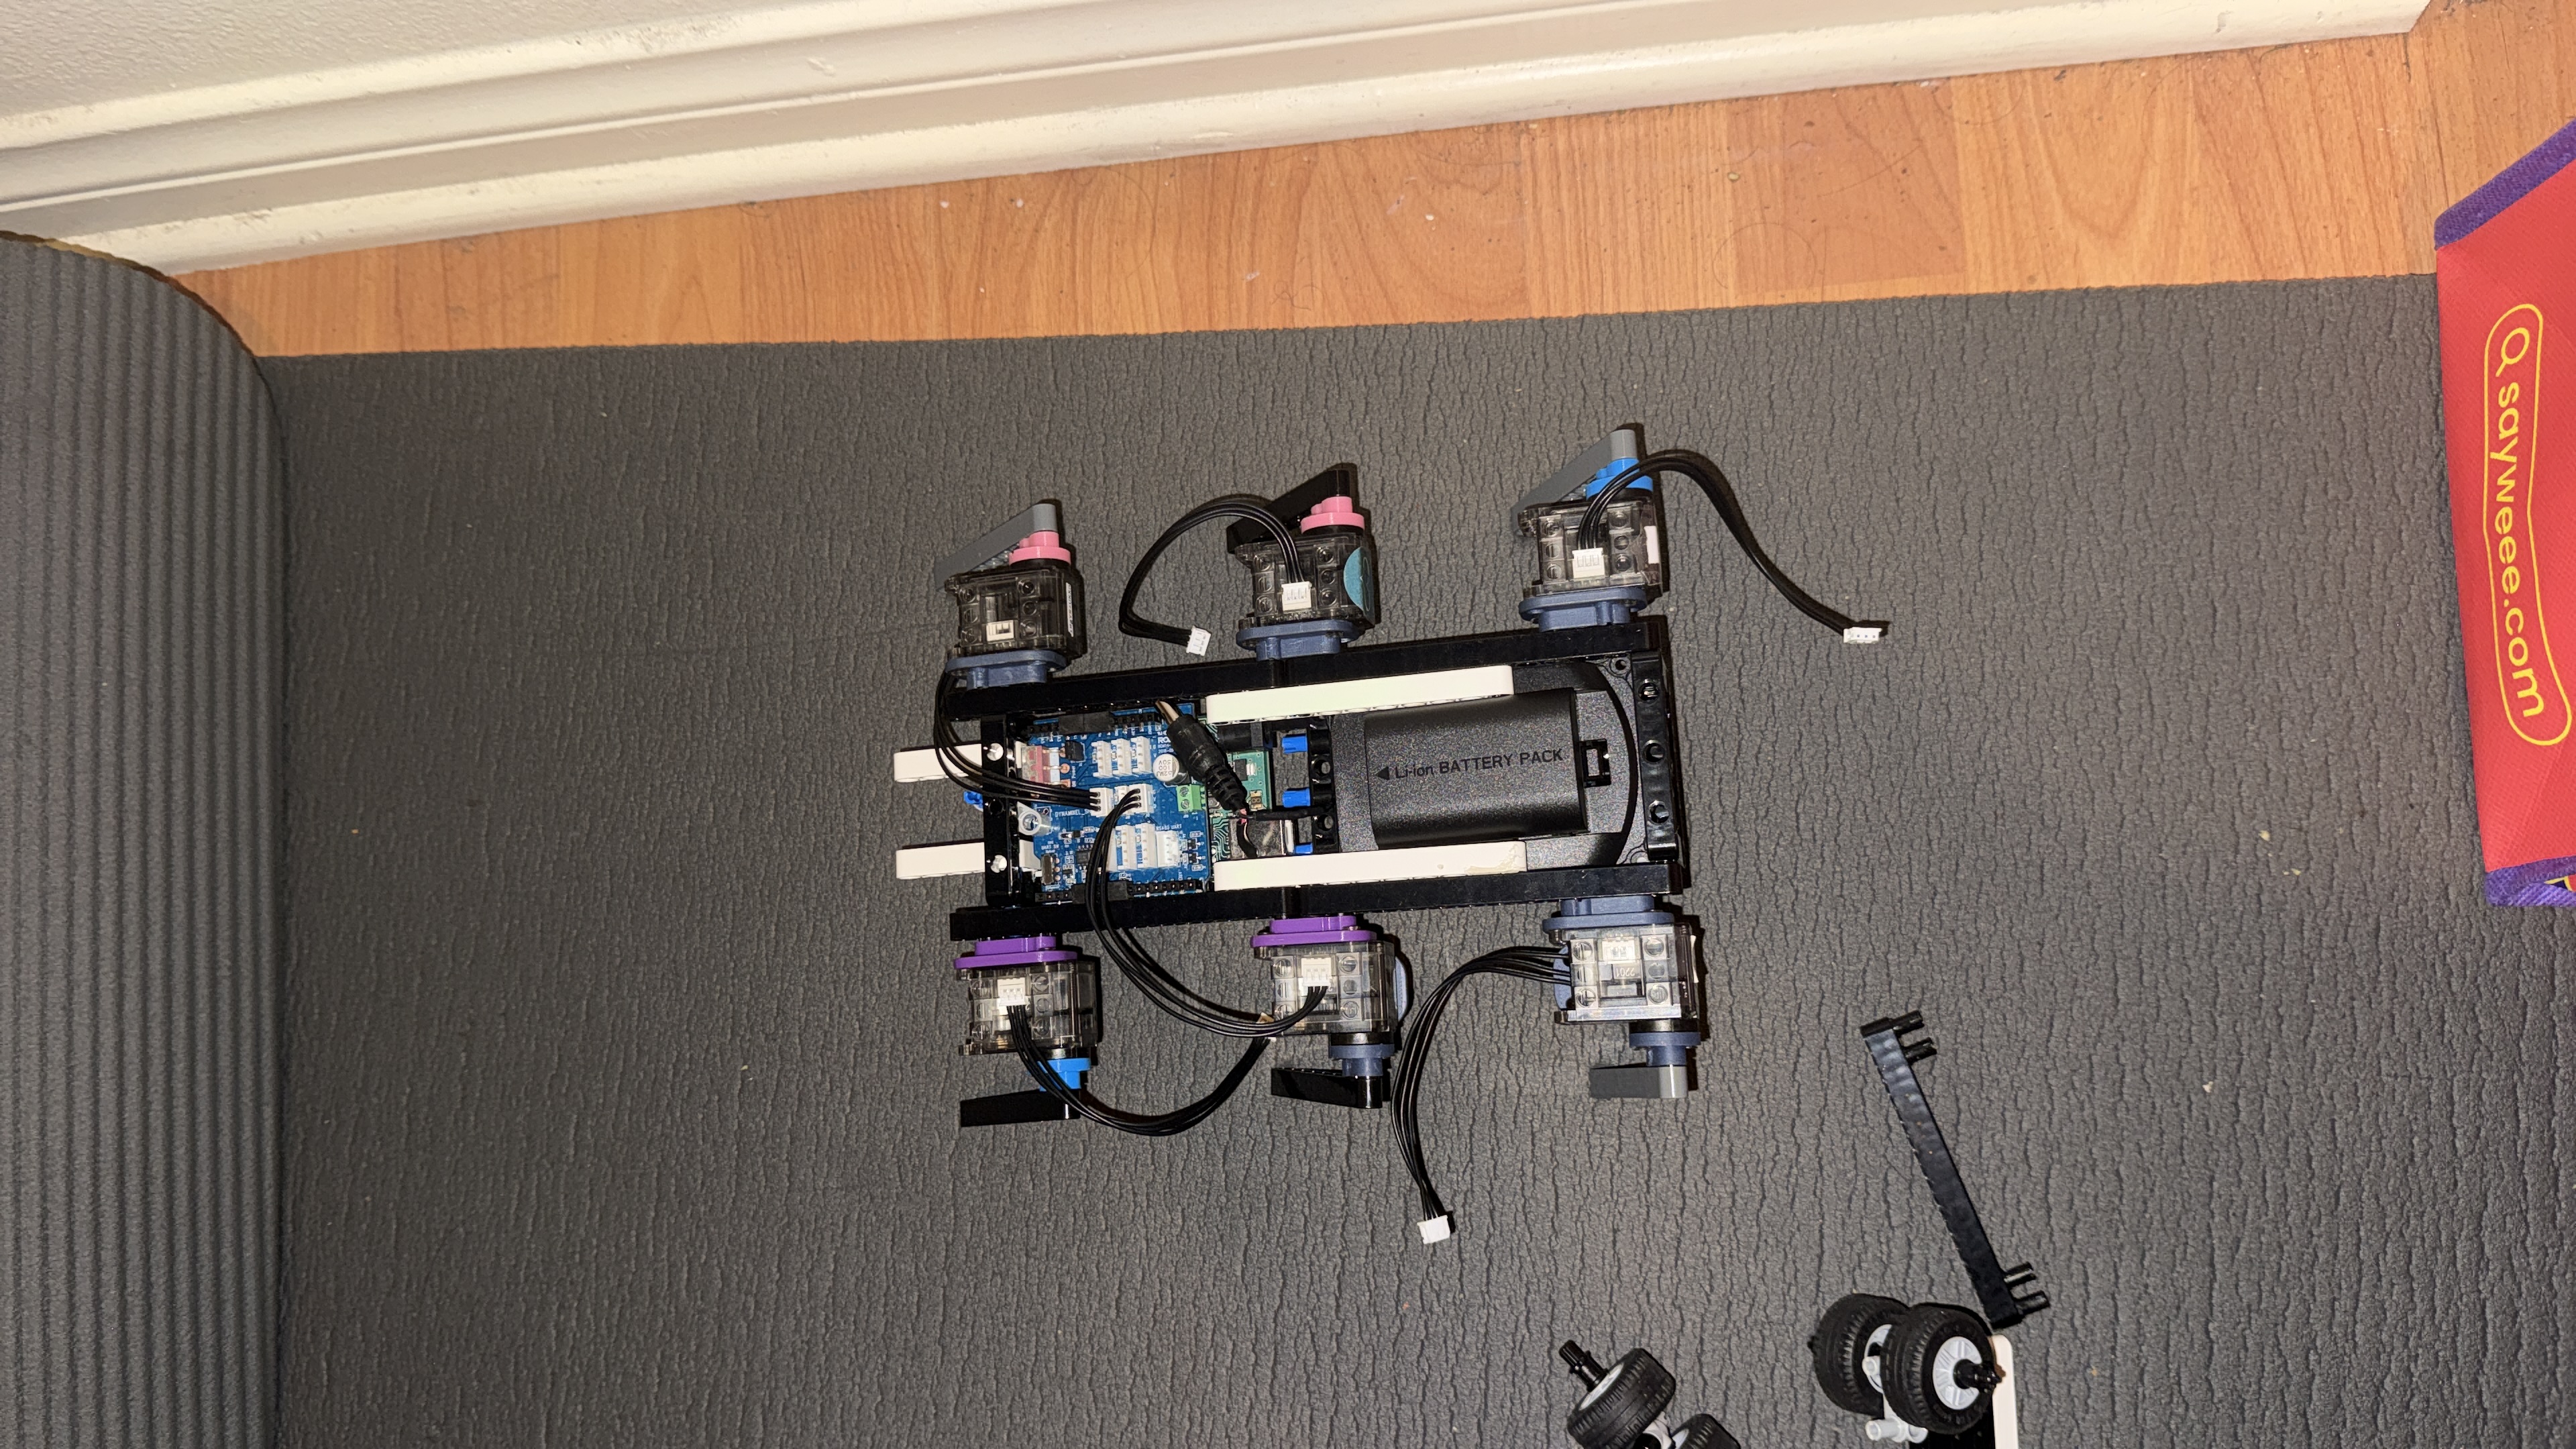
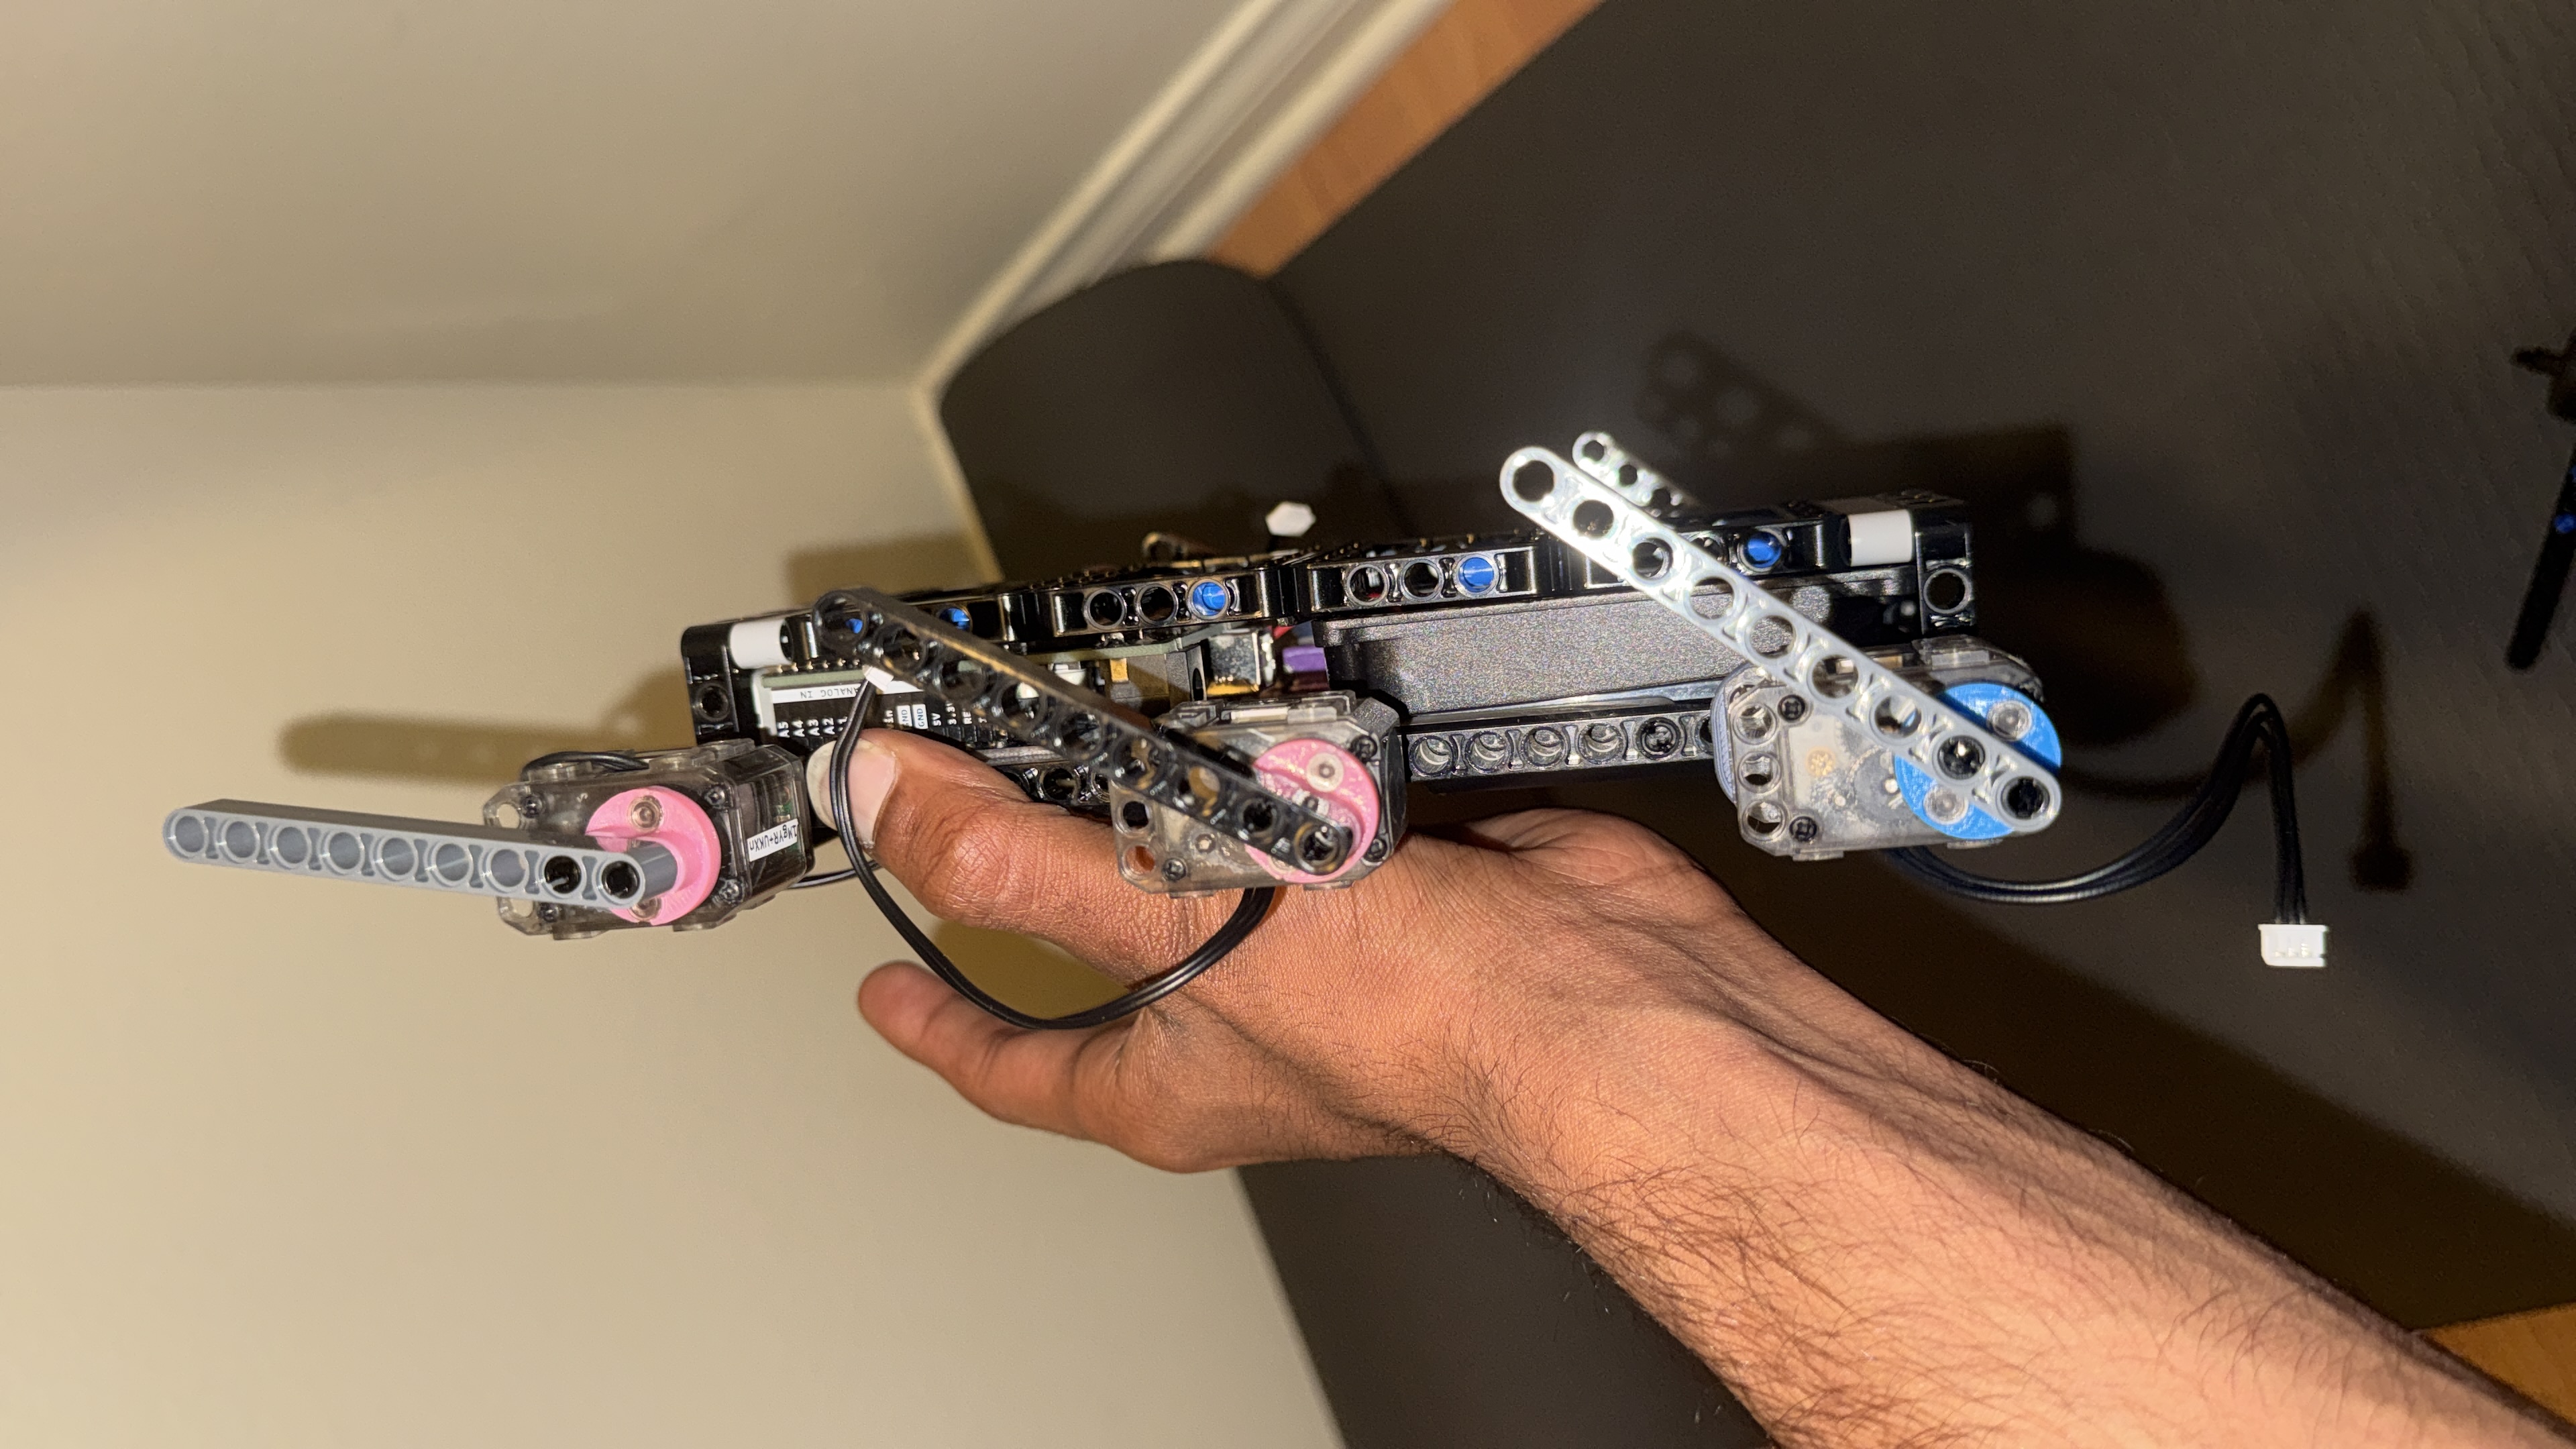
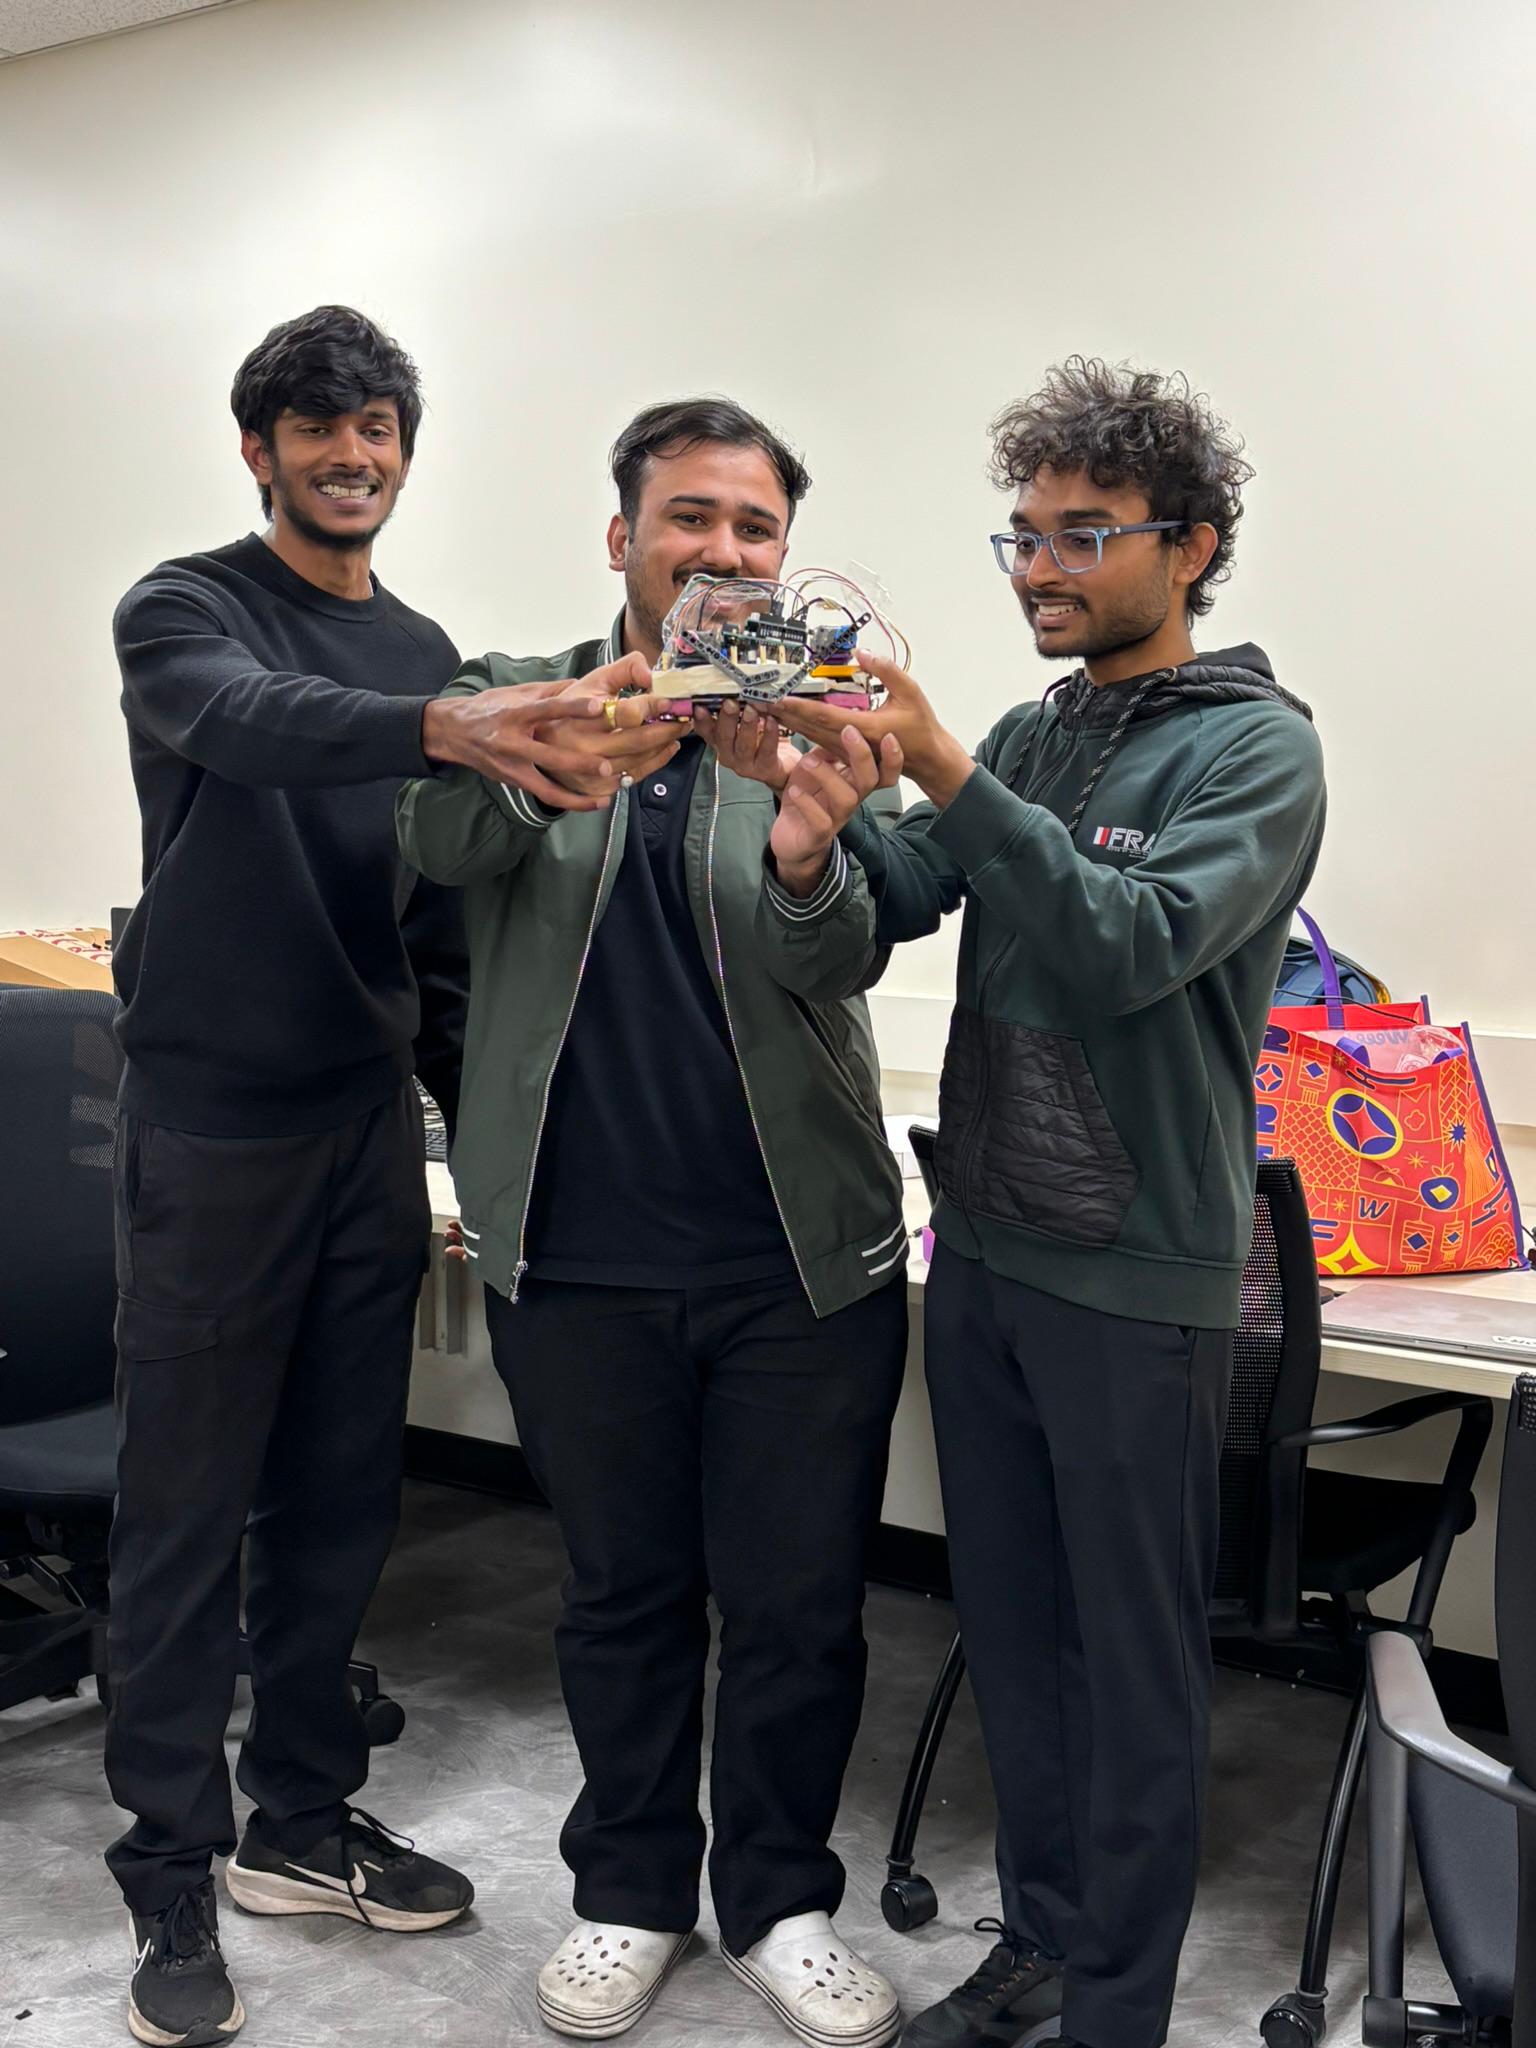
Embedded C++ firmware for a quadruped robot walking on granular terrain. I implemented a Buehler-clock gait and drove DRV2605L haptic actuators for timed vibration during leg swing phases — studying how vibration timing affects locomotion on loose substrate.
Hardware
- 4x Dynamixel XL-320 servos (one DOF per leg)
- 2x DRV2605L haptic motor drivers (front / rear pairs)
- Arduino-compatible microcontroller, Li-ion battery pack
- 3D-printed servo mounts and leg linkages
What I built
- Buehler-clock gait generator with configurable phase offsets
- Haptic actuation synchronized to the swing phase of each leg
- Multiple gait modes (trot, walk, bound) selectable at runtime
- Real-time power-consumption monitoring over serial debug
Testbed
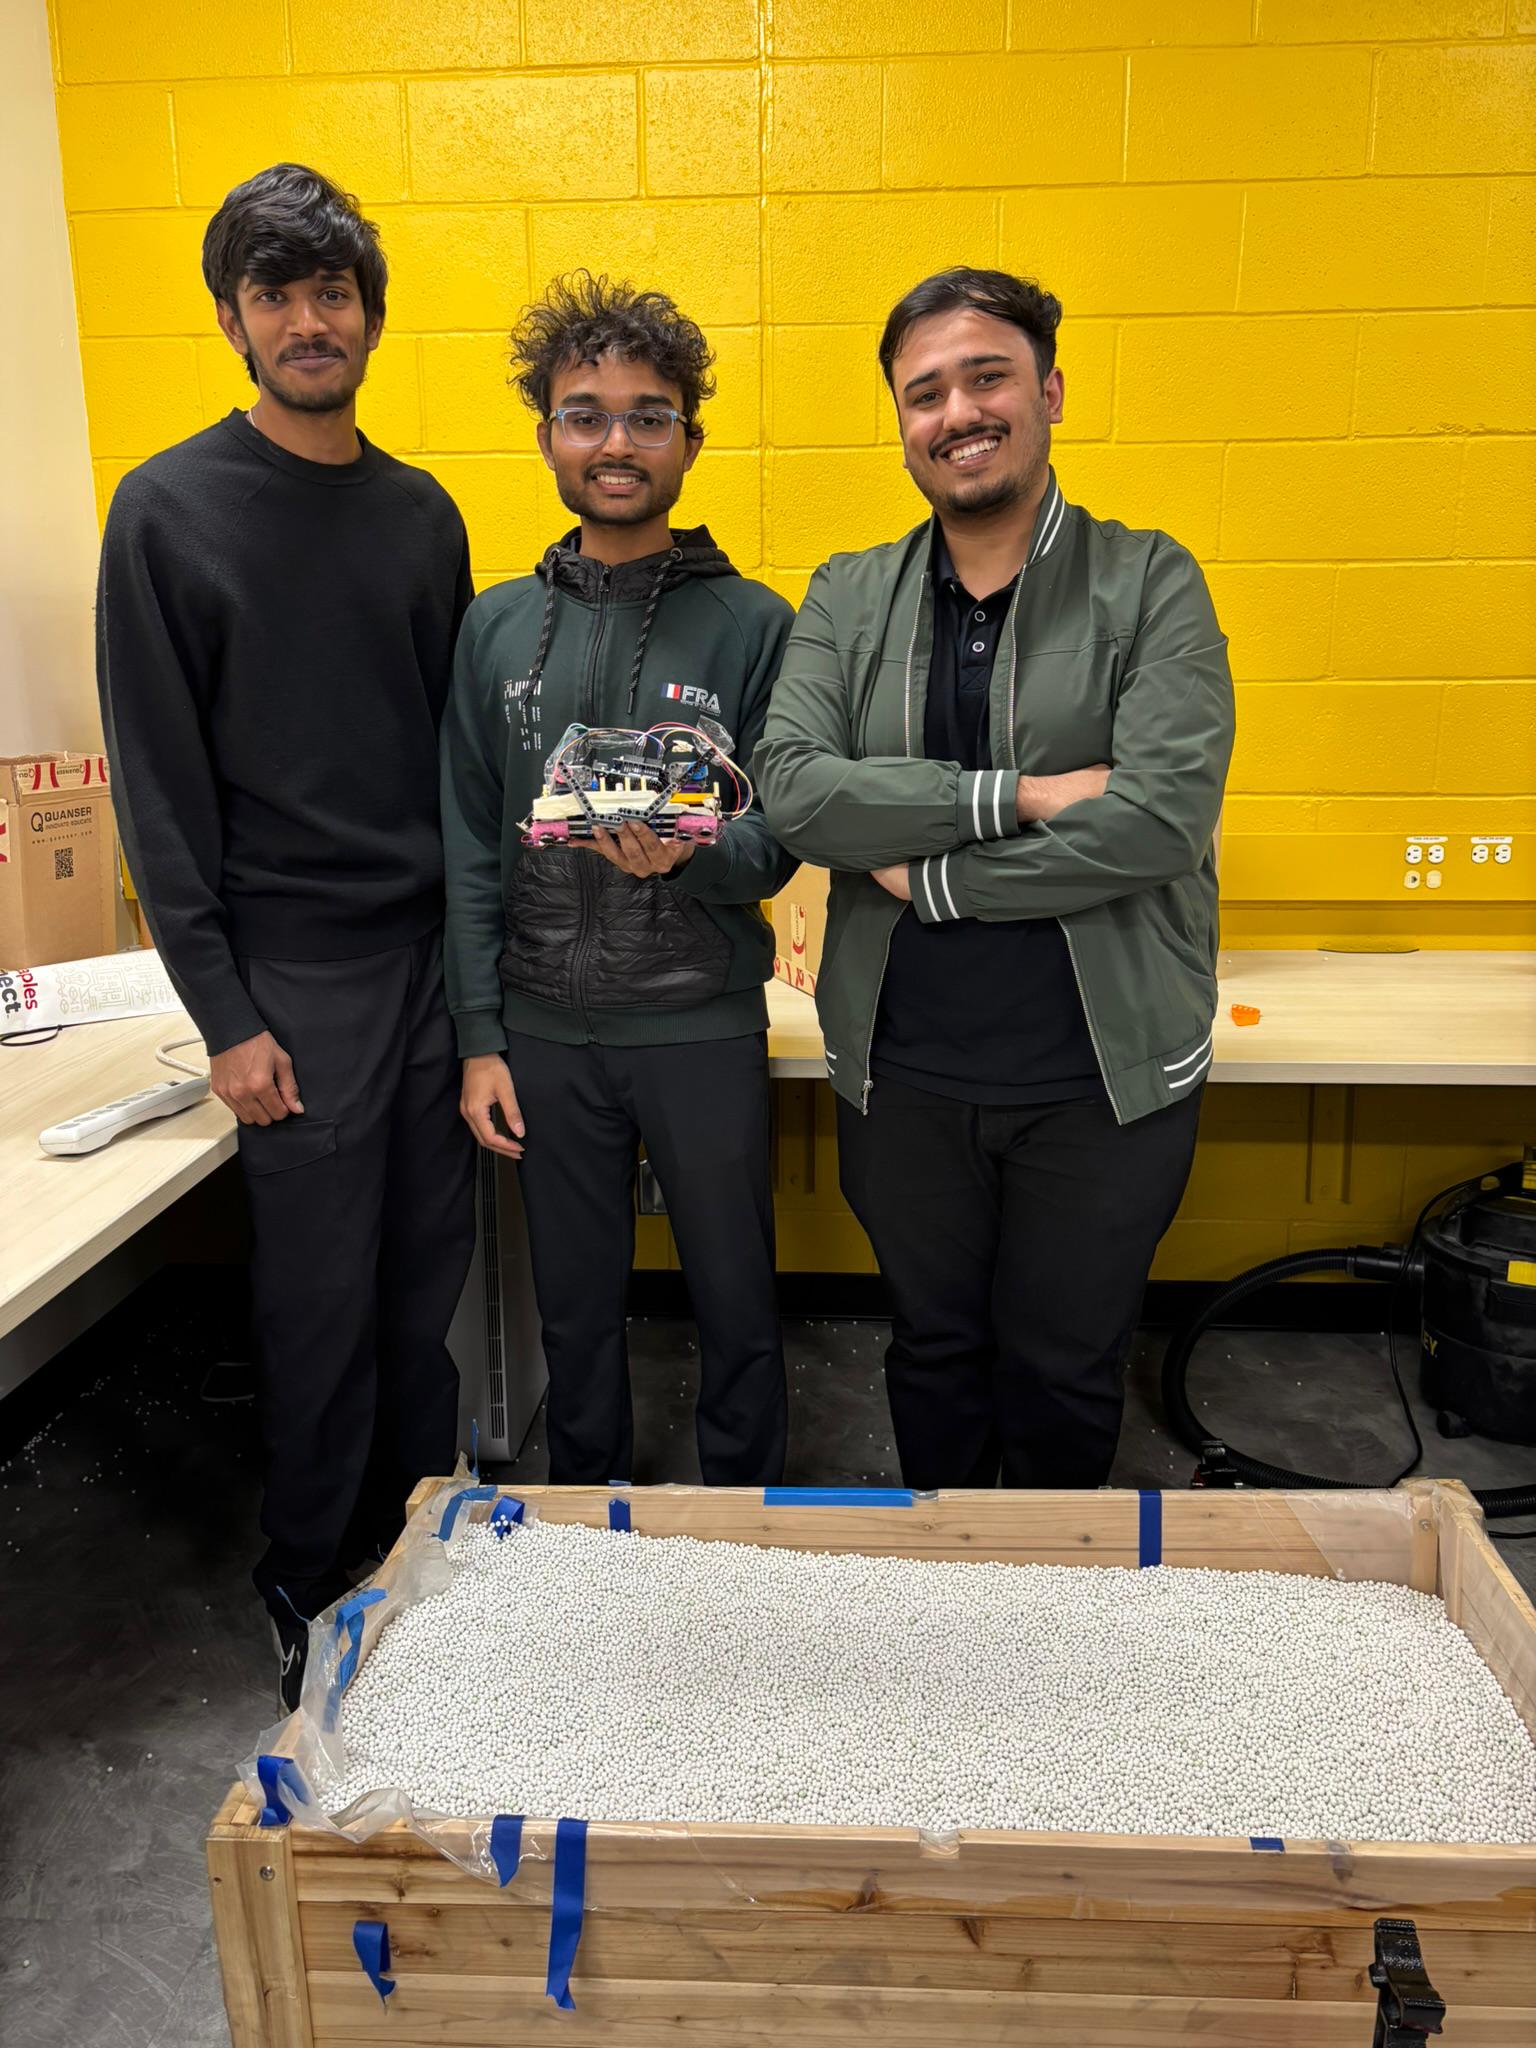
A wooden box filled with beads as a repeatable granular substrate — the robot walked the box while we varied vibration timing and gait, watching which combinations kept it moving instead of digging in.
Built with
Embedded C++ · Robotics · Firmware